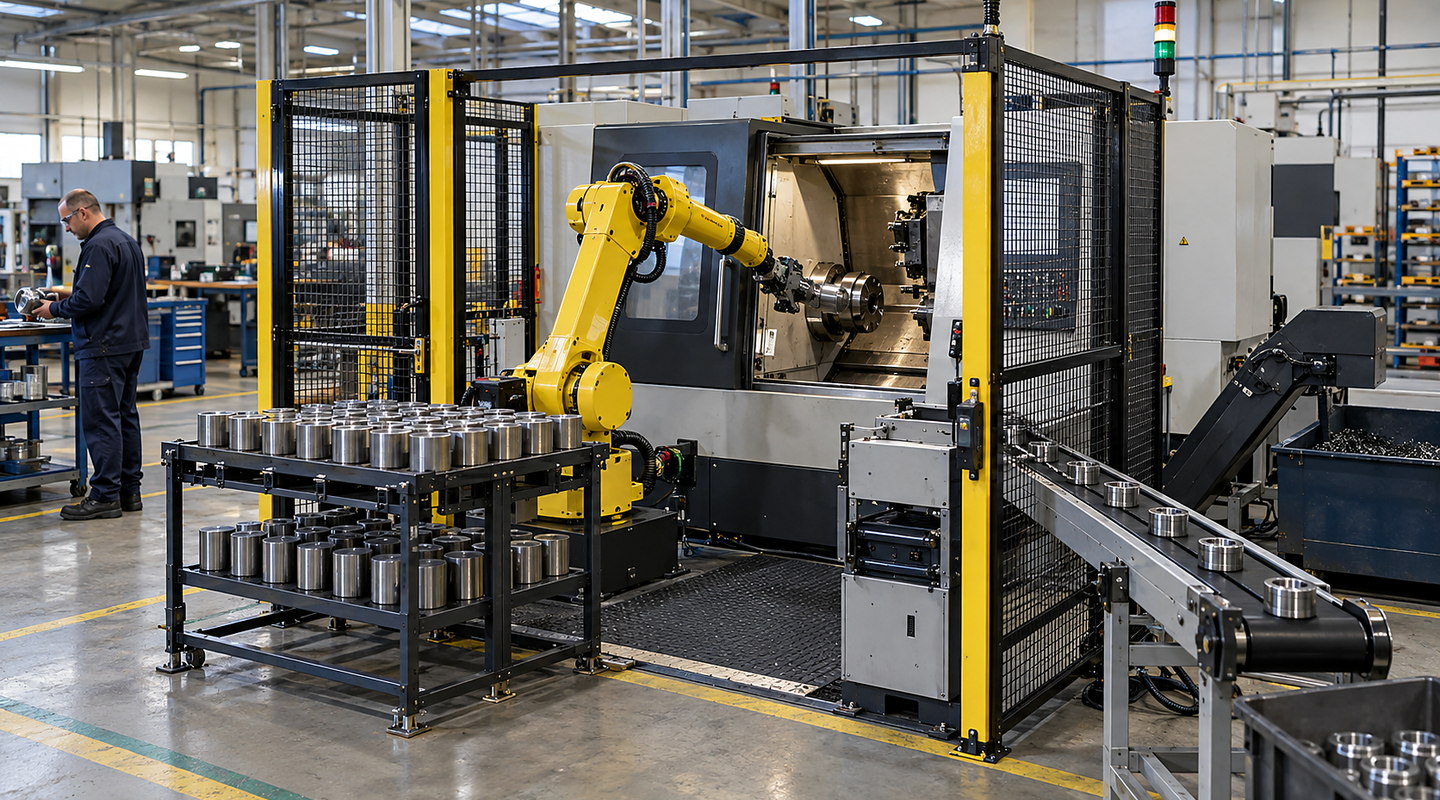
Retrofit or Flexible Cells Involving Existing Robot-Cell Upgrades
Scope robot cell changes around retained and modified equipment, program versions, tooling, interfaces, phased changeover and controlled recovery.
In brief
Define what the retrofit keeps, modifies and replaces, including tooling, fixtures, programs, sensing, services and line interfaces. Record the current configuration, agree the sequence of changes and name the decisions needed before each stage can proceed or production can resume.
Connect the interface and recovery schedule to the acceptance cases. A saved program is only part of recovery: physical changes, settings and affected functions must also be addressed before any earlier production arrangement is reused.
On the production floor
Plan for the conditions your team handles every day — Robot Cell Retrofits
Plan robot cell retrofits around your parts, process, cycle time, tooling, recovery and acceptance criteria. Discuss the highest-risk feasibility questions with Oxford Industrial Automation. For retrofit or flexible cells involving existing robot-cell upgrades, the deciding details include part, product and process variation for existing robot-cell upgrades, required cycle and production pattern and run-off criteria and production evidence.
Details worth resolving early for retrofit or flexible cells involving existing robot-cell upgrades
Question 1
Part, Product and Process Variation for Existing Robot-Cell Upgrades
Define retained, modified and replaced equipment against the proposed new product or process. Keep the current drawings and program/configuration versions as the documented starting point.
Question 2
Arrival Pattern and Presentation
Assess whether existing fixtures and presentation arrangements suit the new parts. Trial the uncertain handling step with representative variation before relying on retained equipment.
Question 3
Required Cycle and Production Pattern
State the available changeover window and production dependencies. Agree which changes can be staged and the checks needed before progressing or resuming a production task.
Question 4
Tooling, Sensing and Process Interfaces
Document tooling, utility, sensing, control and external-system changes with named owners. Identify obsolete items and confirm the actual compatibility of retained interfaces.
Question 5
Operator Access, Recovery and Changeover
Agree backup ownership and the response to an interrupted or unsuccessful change. Include physical tooling/settings and affected functions in recovery; restoring a file alone does not establish readiness to run.
Question 6
Run-Off Criteria and Production Evidence
Run agreed normal, difficult, changeover and recovery cases for the modified scope. Retain the applied configuration, discrepancies, authorised corrections and release decisions with updated operating information.
Your operating cycle
Plan for more than automatic running
Include replenishment, normal production, planned change, short stops, fault recovery, cleaning and maintenance for retrofit or flexible cells involving existing robot-cell upgrades. A fast automatic step can still leave your team with a slow or awkward overall process.
Normal production and variant changes
Replenishment and material presentation
Operator access and safe interventions
Cleaning, maintenance and recovery
Prove the result
Test retrofit or flexible cells involving existing robot-cell upgrades against representative parts, tooling and difficult cycle conditions
Normal production
Run the agreed product or part mix for retrofit or flexible cells involving existing robot-cell upgrades at your intended operating pattern.
Difficult conditions
Include credible extremes for part, product and process variation for existing robot-cell upgrades and arrival pattern and presentation.
Fault and recovery
Show how the proposed solution detects a problem affecting retrofit or flexible cells involving existing robot-cell upgrades, responds safely, informs your team and restarts under control.
Important limits
Be clear about what the trial has shown
Cycle time depends on the complete process rather than robot speed alone.
Part presentation, tolerances and recovery cases must be included in feasibility work.
Collaborative operation or automatic handling cannot be assumed safe without an application assessment.